How a Maker Built Fetch the Robot That Plays a Full Game of Fetch Alone
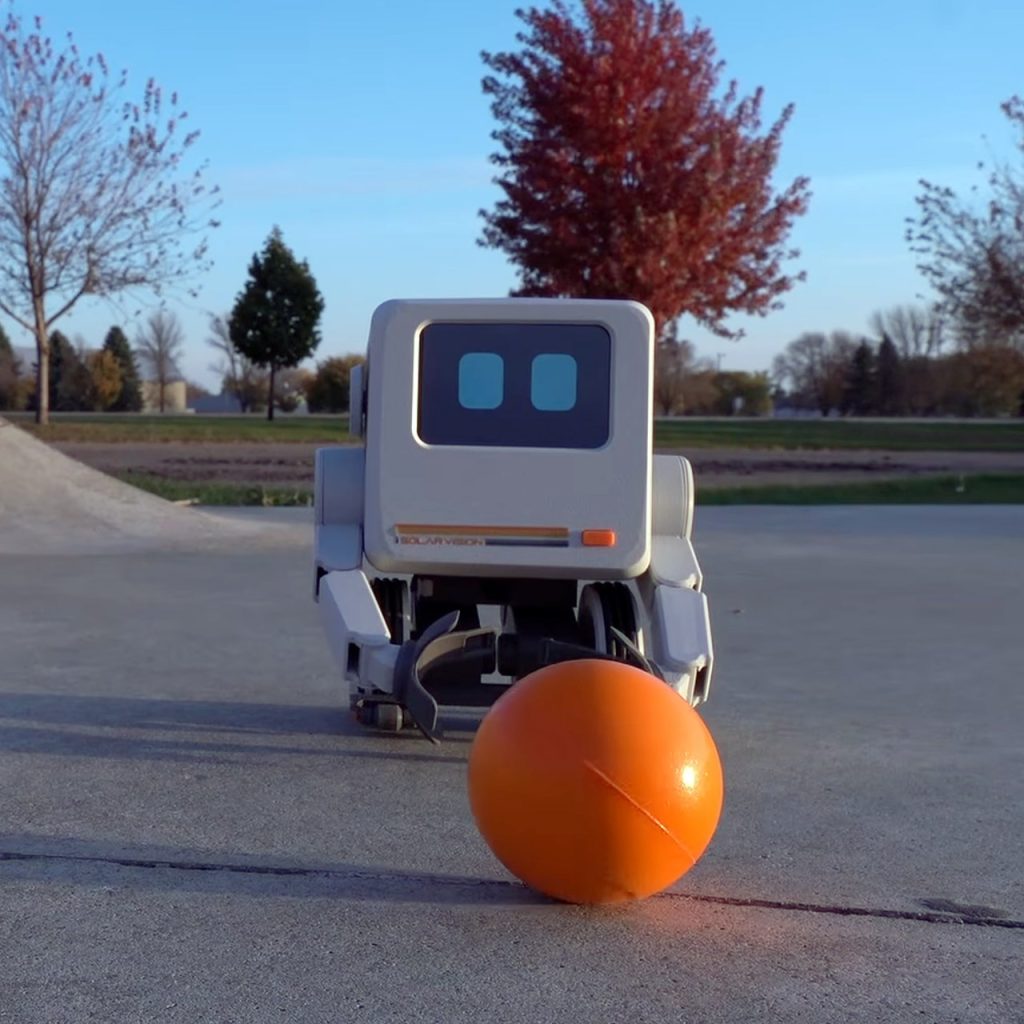
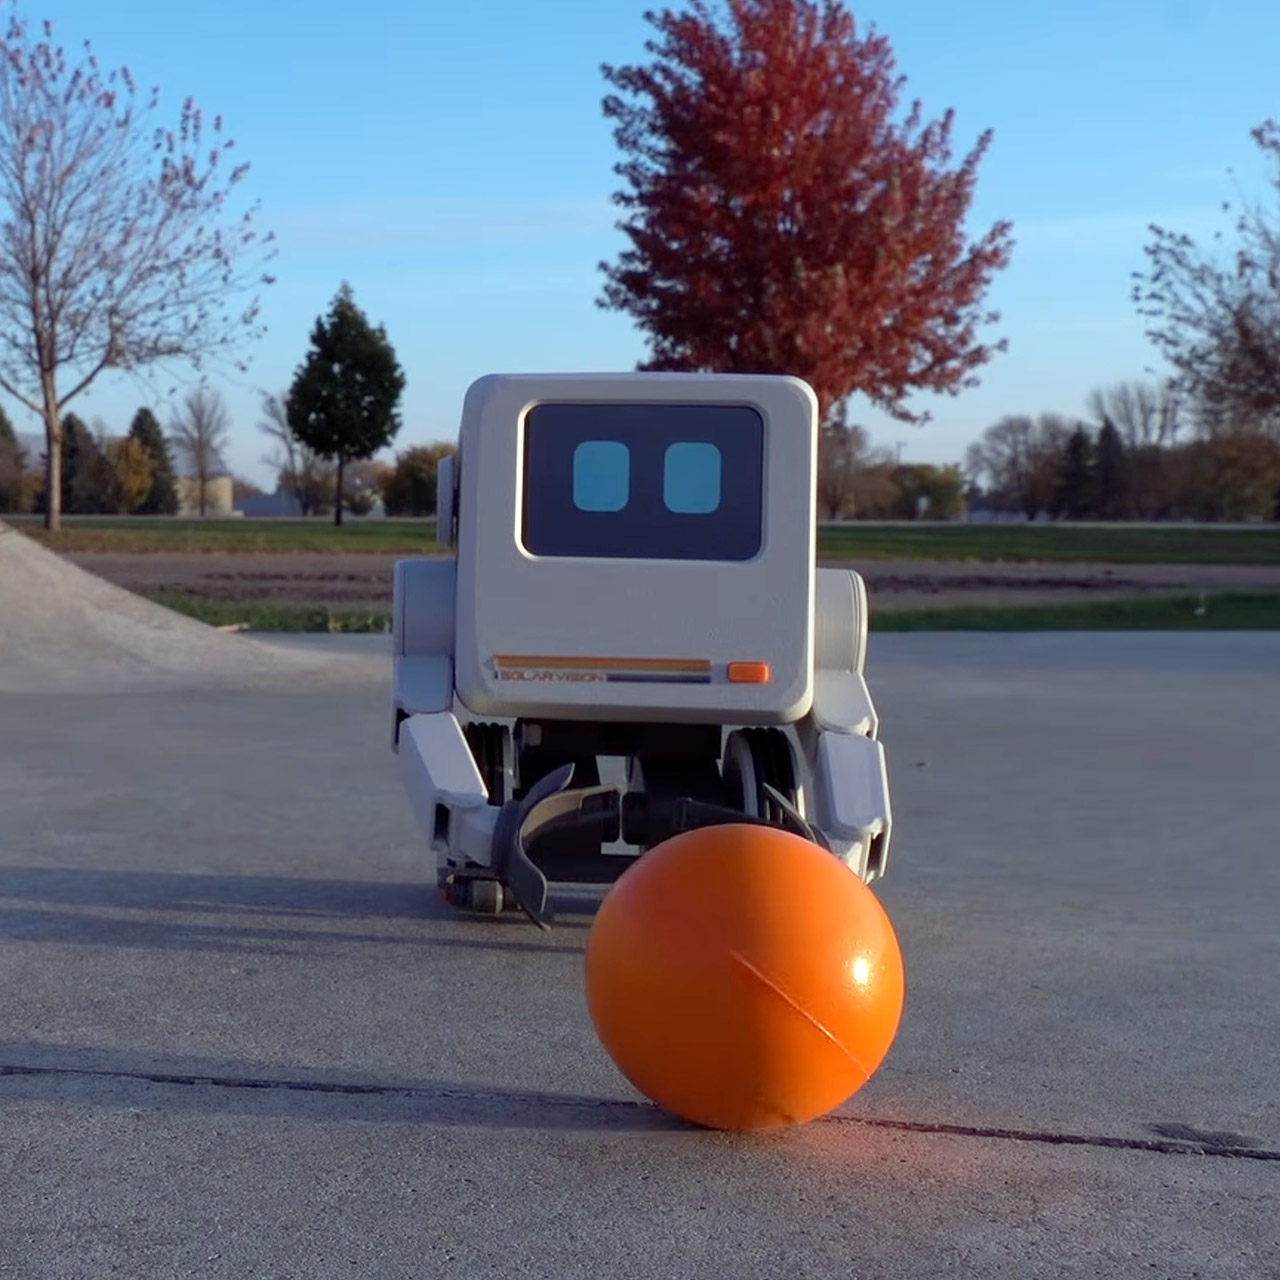
Fetch drives across the floor until an orange ball fills its camera view, then rolls straight toward it and closes two printed arms around the ball. Once the grip holds, the robot turns, scans until it sees a raised hand, and carries the ball back. Sector 07 assembled this complete find-grab-return loop as his first autonomous machine, with parts that totaled about $300.
Sector 07 basically built the body out of 3D printed sections that simply snap and slide into place, requiring only a handful of screws to assemble. The arms just stretch out, grasp the ball, and the contraption rolls along on motor-driven wheels. Manual testing revealed that the arms snapped shut perfectly, and the drive system tracked straight as an arrow before any code was even executed.

Bambu Lab A1 mini 3D Printer + LED Lamp Kit, Ready-to-Use for Beginners | Beginner-Friendly Ecosystem…
- A1 mini + LED Lamp Kit for Creative Light Projects: Bring your ideas to life with the included LED Lamp Kit. Simply print compatible lamp models and…
- The Perfect 3D Printer for Beginners: A1 mini 3D Printer is designed to make 3D printing easy from day one with automatic calibration, simple setup…
- Experience the Bambu Lab Ecosystem: Access MakerWorld’s huge library of ready-to-print models, manage prints through the Bambu Handy app, and enjoy…
An Arduino UNO Q is sitting in the center of the entire setup. One of the CPUs runs Debian Linux, which handles the camera feed as well as all of the vision things. A second, separate microcontroller is in charge of moving the motors and servos with extremely accurate timing. This allows the robot to know what’s going on and begin moving before anything becomes bogged down while waiting for the other to catch up.
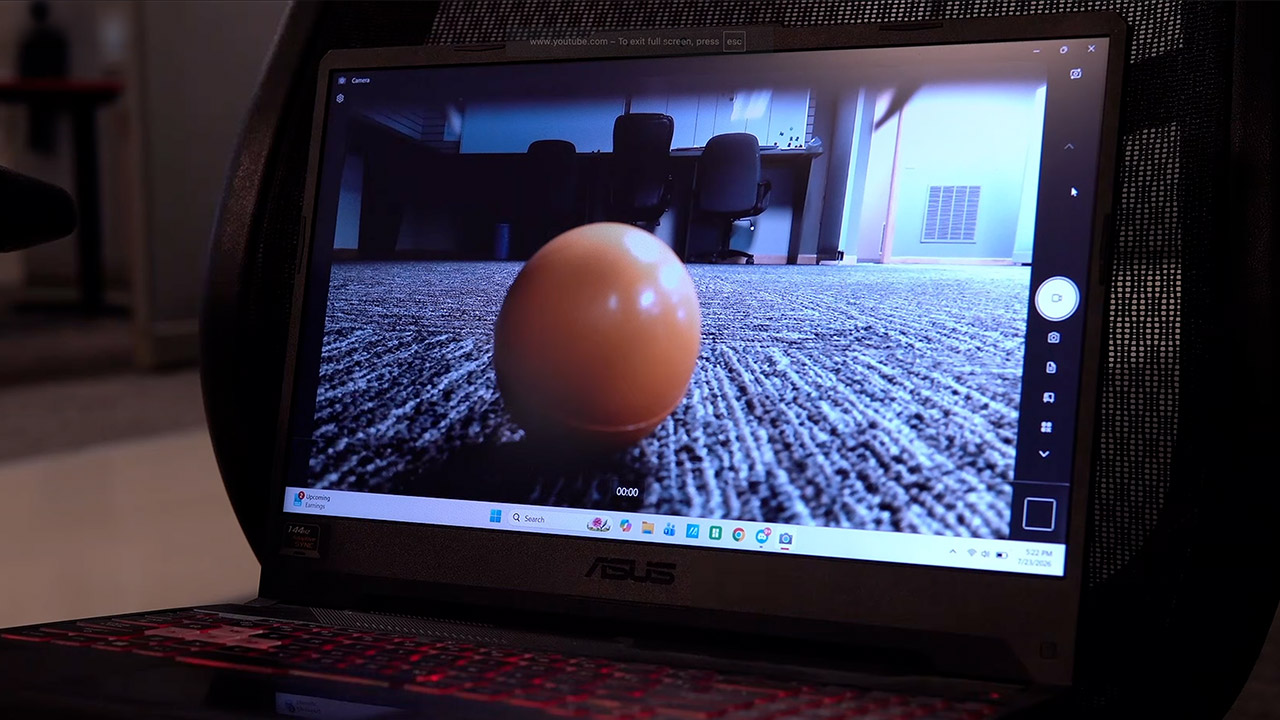
Sector 07 trained the visual model using Edge Impulse and YOLO-Pro, a unique detector designed to fit into smaller machines. He simply needed to educate it to recognize an orange ball and a human hand. He took roughly 200 photos of each, all taken with the robot’s camera under a variety of lighting situations and on different floors. And all against a variety of backgrounds, yielding some impressive outcomes for a robot that only needs to play fetch a few times. The model just generates some bounding boxes, and the code directs the wheels toward the ball or the hand while moving the arms at the appropriate distance.
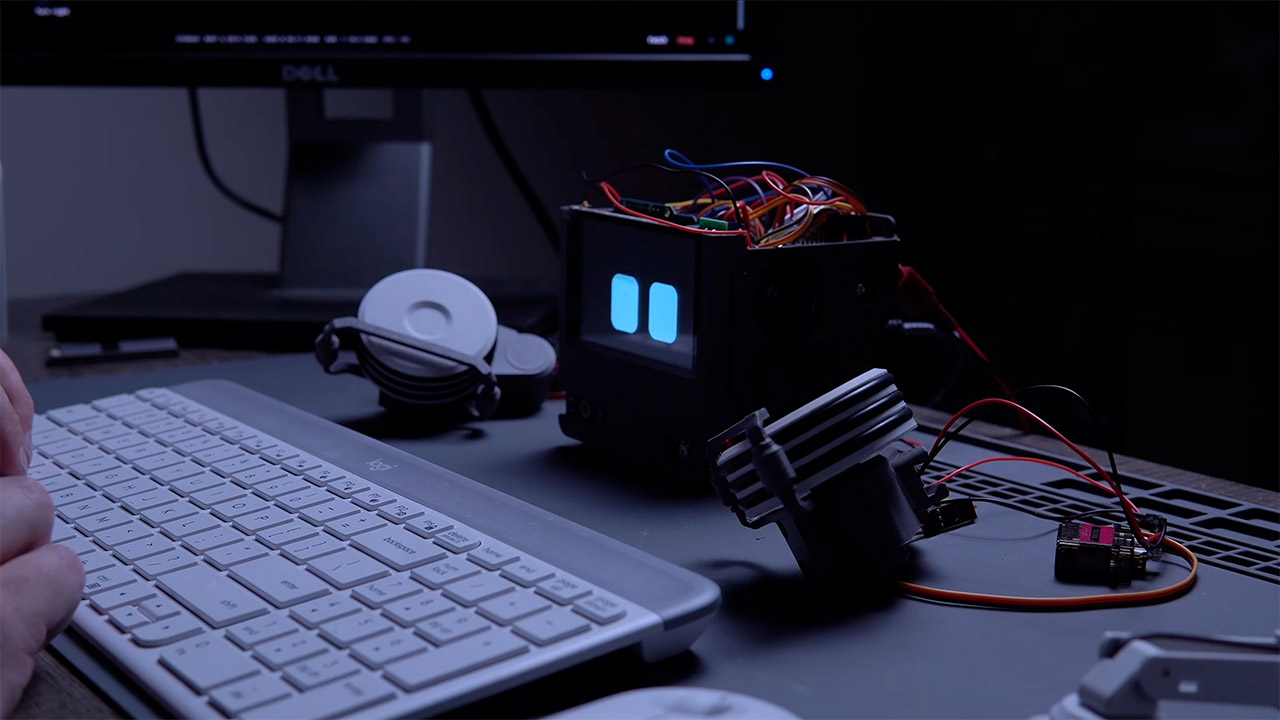
There’s a small screen on the front that shows some animated eyes that change expression as it works, and the ear-like objects on the robot’s side move in accordance with its state. The robot even comes with some short lines in a voice that it just used from ElevenLabs. So when it sees the ball, it says something similar, and when it delivers the ball, it also says makes a sound. It gives the creature some personality and allows it to comment on its own development during each round.
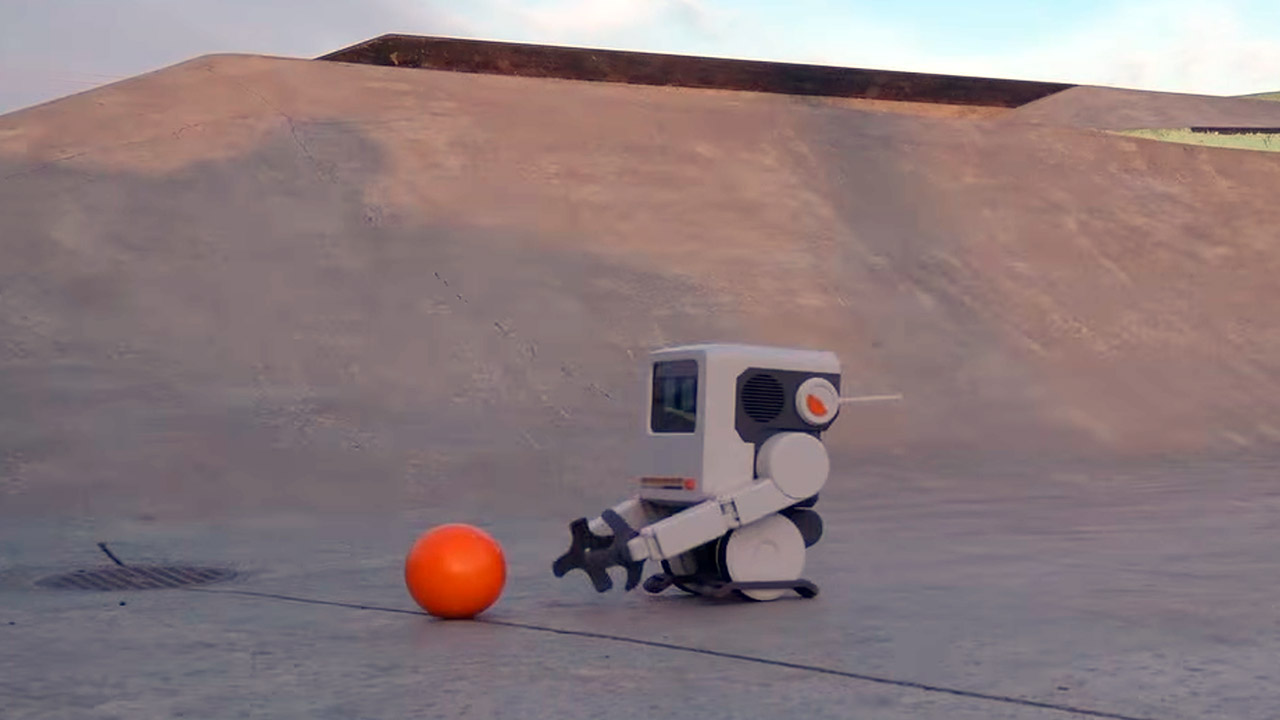
Of course, testing it out required a lot of runs to catch all of the edge cases where the robot would lose the ball in bright light or drop it while attempting to release it, but a few tweaks to the motor speeds, grip timing, and the model’s confidence levels fixed the majority of those issues. Now the robot is ready to go and can play an entire game of fetch on its own. Sector 07 has released the entire project as open source. On Arduino Project Hub, you can get print files, code, a components list, and some of his notes on how to put it all together. Arduino sponsored the entire event, and the files are still free to download.
How a Maker Built Fetch the Robot That Plays a Full Game of Fetch Alone
#Maker #Built #Fetch #Robot #Plays #Full #Game #Fetch